Local-First & CRDTs
Zoom
Architecture Strategy
Fully client-side. Pinia for reactive state, IndexedDB via idb for persistence, Service Worker for offline caching (vite-plugin-pwa).
Key Engineering Trade-off
Zero server means no cross-device sync. Users export and import JSON files manually instead.
Performance Metric
Instant 0ms timer loop & mutation resolution. Fully functional without internet.
Storage Subsystem
Browser IndexedDB (via idb abstraction)
Local Focus
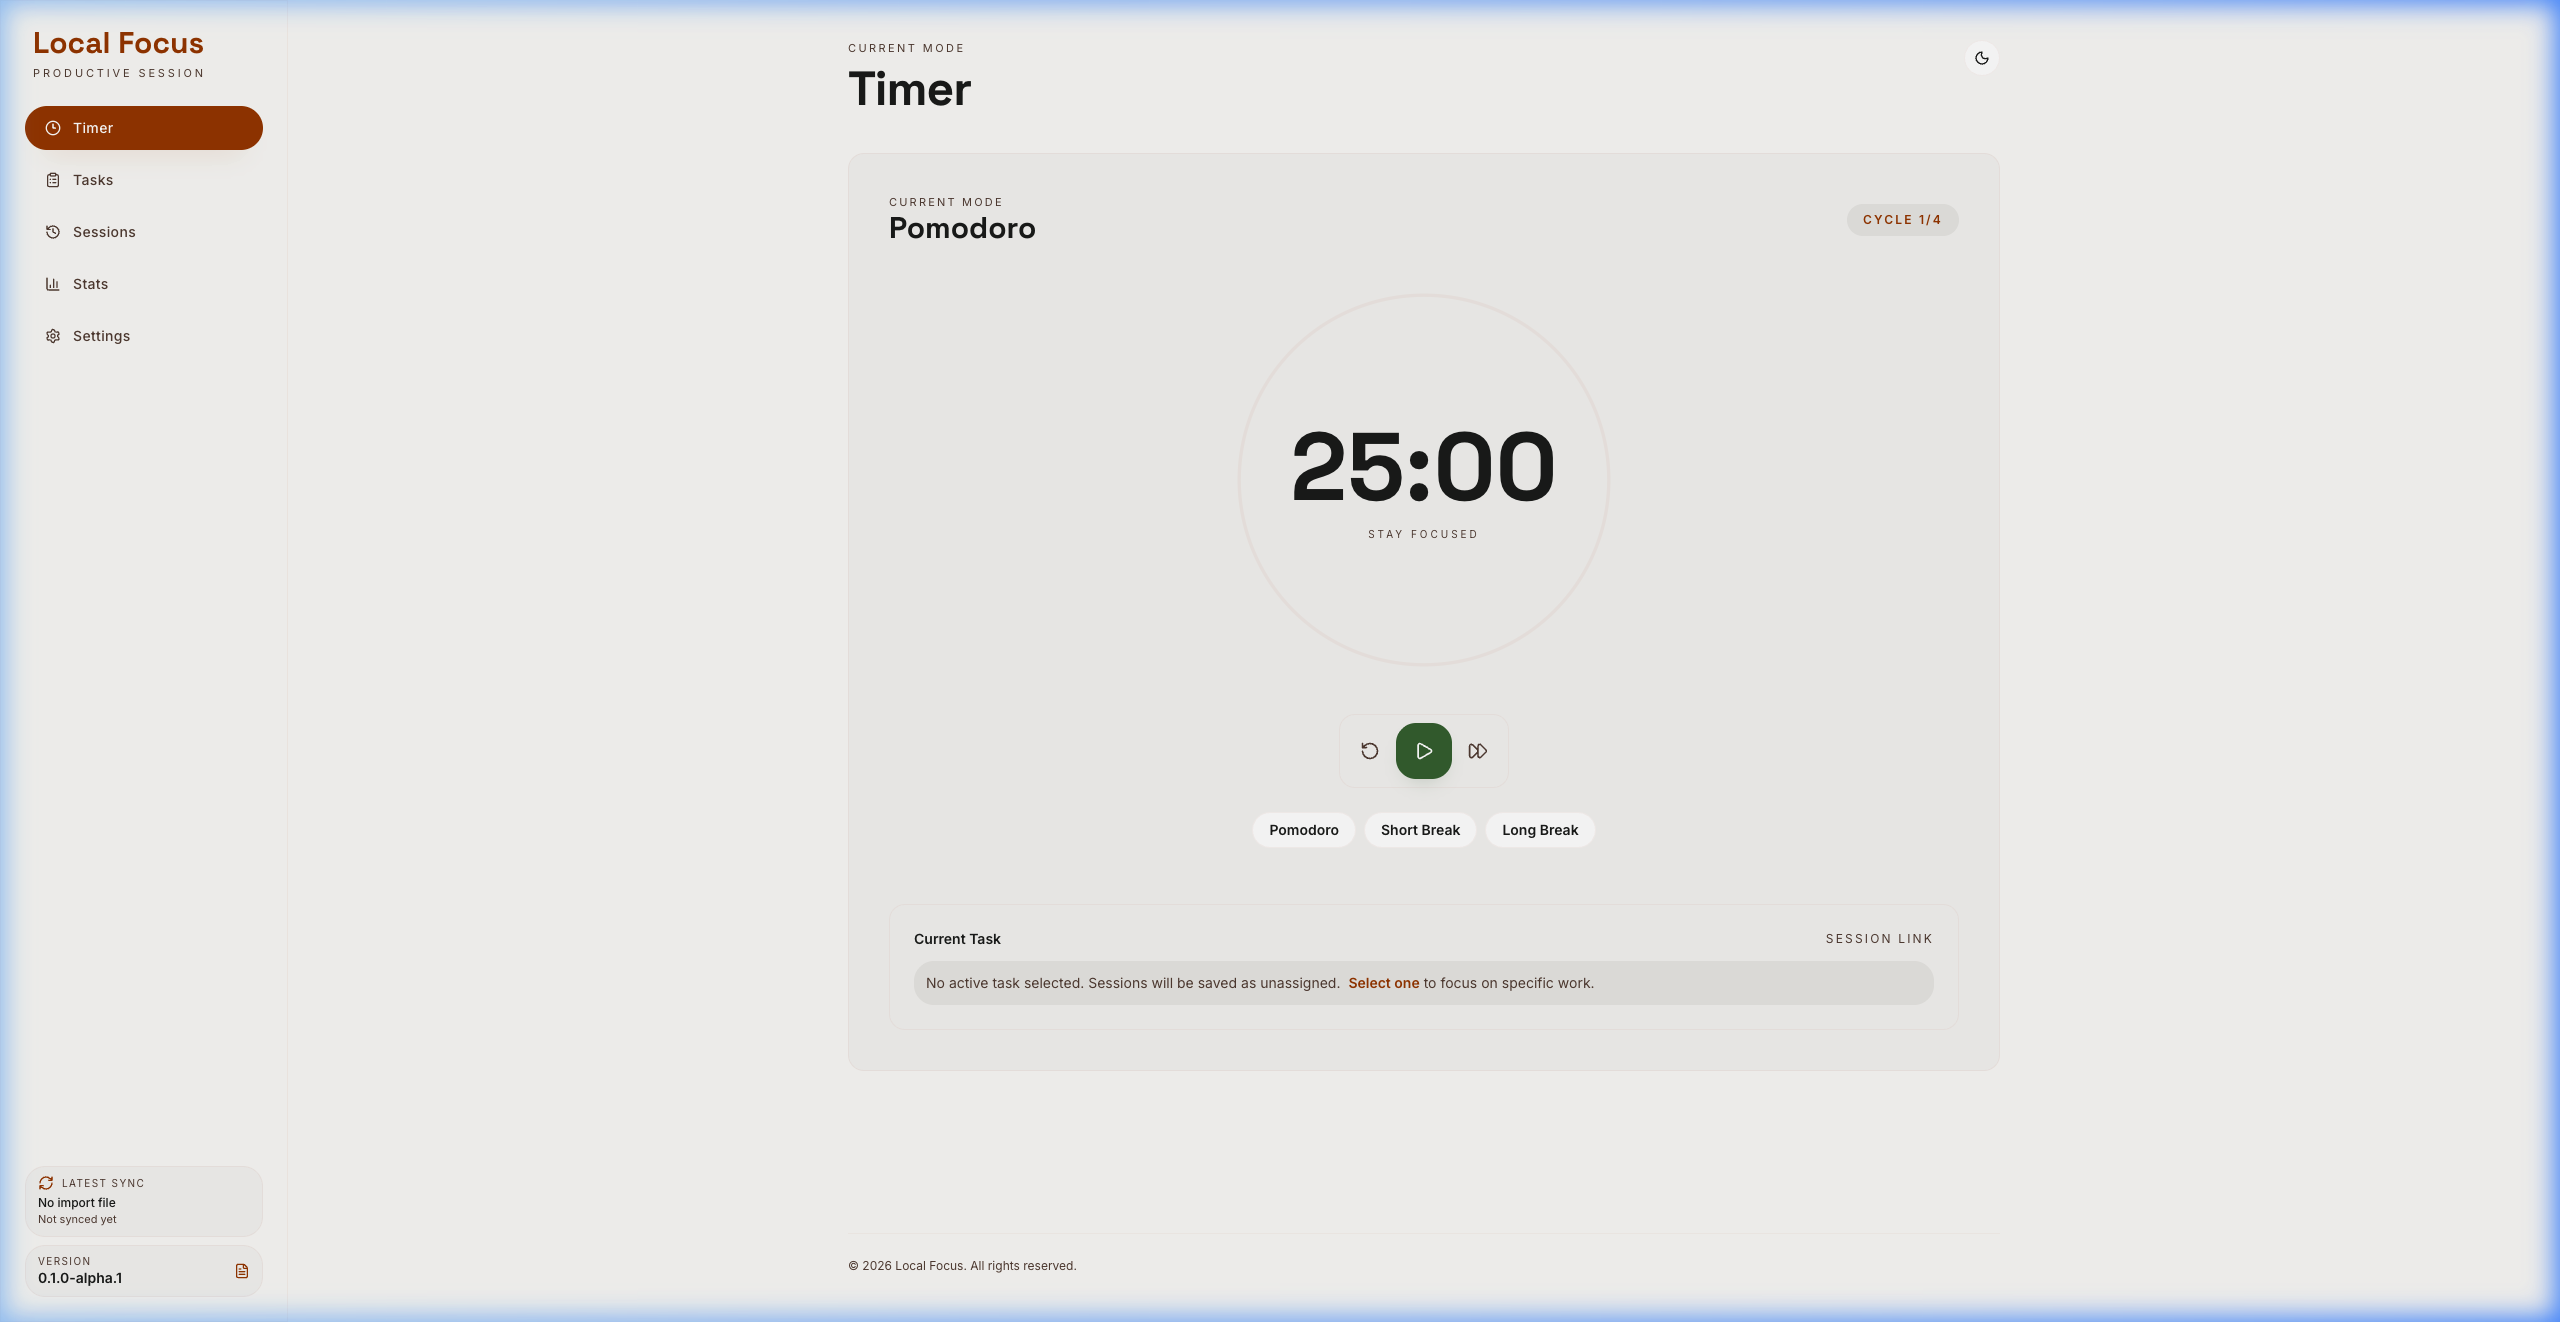
Offline-first Pomodoro timer and task tracker. All data stays in the browser.
The constraint was simple: no server, no account, no tracking. A Pomodoro timer with task-linked sessions and productivity stats, backed entirely by IndexedDB. Works offline out of the box via PWA caching. Backup and restore uses portable JSON file exports.
0% (Local-Only) Cloud Dependence
IndexedDB (idb) Storage Engine
100% PWA Offline Ready
Zero Tracking Privacy Policy